




Eight-wheeled Drive Robot Chassis
Load Capacity: 1000kg
Total Vehicle Weight: 360kg
Top Speed: 15km/h
Runtime: Depends on the battery and usage
Parameter
|
Wading Depth: |
10m |
|
Load Capacity: |
1000kg |
|
Total Vehicle Weight: |
360kg |
|
Top Speed: |
15km/h |
|
Runtime: |
Depends on the battery and usage |
|
Battery Specification: |
Optional |
|
Intelligent Obstacle Avoidance: |
Radar obstacle avoidance or ultrasonic obstacle avoidance |
|
Tracking Distance: |
No |
|
Fuel: |
Electro |
Product Description
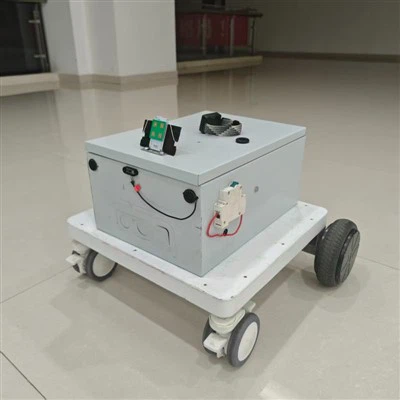
The Eight-wheeled drive robot chassis Amphibious Robotic Platform represents a breakthrough in all-terrain robotics, featuring a unique eight-wheel configuration with exceptional aquatic capabilities. The platform's sealed, low-profile chassis resembles a protective shell, providing complete water submersion protection up to 10 meters depth. Each side of the rectangular frame integrates a linear arm assembly with dual wheels, creating a distinctive "four-rail" suspension system that maintains contact across irregular surfaces.
Operating through standard 4G cellular networks, this platform delivers reliable remote control capabilities without line-of-sight limitations. The combination of balanced buoyancy, strategically positioned thrusters, and independent wheel control enables seamless transition between terrestrial and aquatic environments, making it ideal for missions requiring true amphibious
Feature
|
True Amphibious Design |
IP68 certified housing enables operation at 10-meter depths with automatic ballast management |
|
Multi-Surface Mobility |
Eight-wheel independent suspension with articulated arm system conforms to uneven terrain |
|
Beyond-Line-of-Sight Control |
4G cellular connectivity allows global operation from any location with network coverage |
|
Stable Platform Architecture |
Low center of gravity and wide stance provide exceptional stability on land and in water |
|
Extended Mission Capability |
Dual-power system supports 8-hour terrestrial or 5-hour aquatic operation |
Design Philosophy
- Unified Environment Approach: We rejected the conventional compromise between terrestrial and aquatic performance, designing instead a system that performs optimally in both domains without reconfiguration or modification.
- Adaptive Contact Geometry: The linear arm suspension system maintains constant ground contact through independent articulation, while the wheel positioning creates natural buoyancy chambers for flotation stability.
- Connectivity-Based Operation: By leveraging existing cellular infrastructure rather than limited-range radio systems, we've eliminated the distance barriers that traditionally constrain remote operations.
Application Scenarios

Marine Research & Inspection
Underwater infrastructure examination of dams, bridge foundations, and pipeline systems
Coastal and freshwater research with continuous water-to-land transition capability
Search & Rescue Operations
Flood response missions with ability to navigate submerged urban areas and access isolated locations
Missing person recovery in lakes, rivers, and coastal regions with extended underwater search capability
Environmental Monitoring
Watershed management studies tracking pollution movement across land-water boundaries
Ecological surveys in intertidal zones, wetlands, and sensitive shoreline habitats
Industrial Infrastructur
Offshore facility inspections below waterline while maintaining deck mobility
Reservoir and water treatment plant maintenance with complete aquatic access
Security & Defens
Port and coastal security patrols with stealthy underwater approach capability
Border surveillance across river boundaries and varied terrain conditions
Frequently Asked Questions
Q: What is the maximum operating range when using 4G control?
A: The platform can operate anywhere with cellular signal coverage, with no distance limitation. However, latency may increase in remote areas with weak signal strength.
Q: How does the suspension system improve terrain adaptability?
A: The articulated arm design allows each pair of wheels to move independently, enabling the platform to maintain ground contact on rocks, debris, and irregular surfaces-conditions that would render rigid axles ineffective.
Q: What optional load configurations are available for special applications?
A: Configurations include a water sample collection system, sonar imaging, machinery, and a sensor array capable of underwater data collection.
Q: How is the platform transported and deployed?
A: Its compact design is compatible with standard vehicle trailers. An optional docking station is available, supporting automatic launch and recovery from shore-based locations.
Hot Tags: eight-wheeled drive robot chassis, China eight-wheeled drive robot chassis manufacturers, metal chassis for robot, 4 wheel chassis kit, robot chassis parts, Outdoor Robot Chassis, aluminium robot chassis, robot arm chassis
Previous
Tank Tread RobotNext
No InformationYou Might Also Like


Send Inquiry